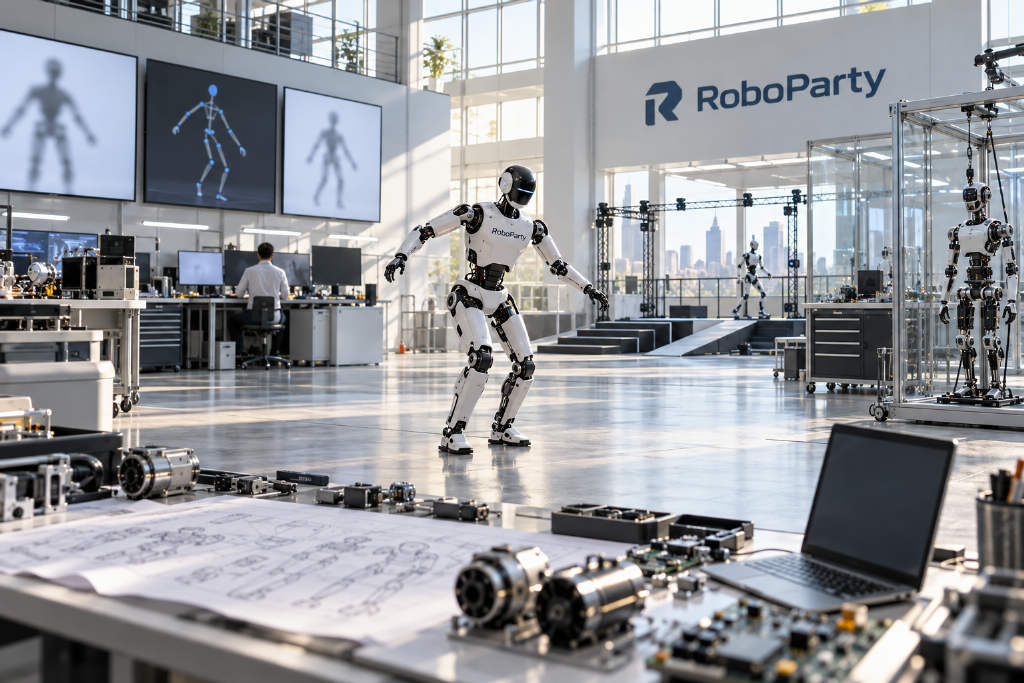
RoboParty open-sources humanoid robot RP1 with mechanical designs and motion stack
RoboParty has officially released RP1, a fully open-source humanoid robot platform that spans both hardware and software. According to Techub News, the project opens access to mechanical drawings, the electrical system, in-house joint modules, low-level control, simulation training, and deployment tools, giving developers a complete R&D path from hardware to software. RP1 stands 135 centimeters tall and has 24 to 30 degrees of freedom. The company has already demonstrated several real-world motion capabilities on the robot, including continuous walking, motion tracking, disturbance recovery, and getting up after a fall. RoboParty also open-sourced hhtools for human motion retargeting, along with URDF/MJCF models and related resources, while building PartyOS as an open development base. The company said it wants RP1 to serve as an open R&D platform for research institutions, universities, and embodied model companies, with the goal of lowering hardware adaptation costs and improving development efficiency. The item was cited by Techub and attributed to QbitAI.