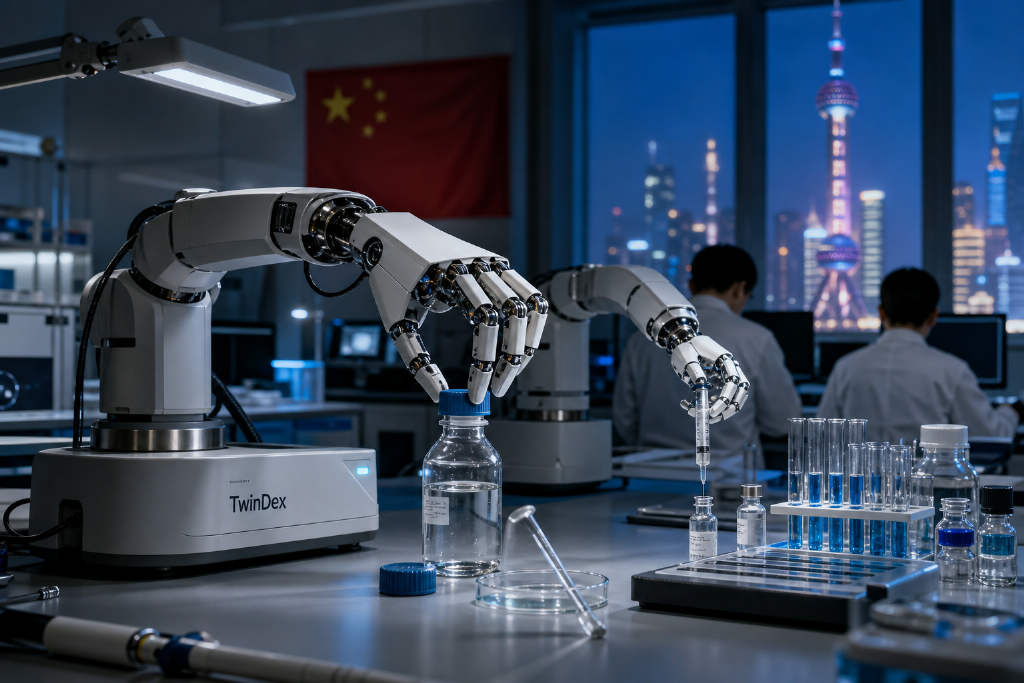
Zibianliang2026-09-03 02:47:11TwinDex debuts with zero robot teleoperation data in post-training for fine manipulation tasksChinese robotics company Zibianliang has introduced TwinDex, a dexterous manipulation system that it says can complete post-training without any real-robot teleoperation data. In the demo, the robot performed a full chemistry experiment workflow, including unscrewing caps, using a syringe, handling pipettes and test tubes, guiding liquid with a glass rod, and mixing for observation. The sequence covered 24 sub-actions across three tools and required repeated bimanual coordination, tool switching, millimeter-level positioning, and stable force control. According to the company’s published results, TwinDex replaces the conventional need for robot-body teleoperation data with a few hundred body-free data samples. It also claims data collection efficiency of about 5.3x that of traditional real-robot teleoperation in terms of valid trajectories produced per unit of time. Zibianliang said policies trained on body-free data improved at the same rate as those trained on real-robot teleoperation data as dataset size increased, eventually converging to similar performance. TwinDex combines a three-finger, nine-degree-of-freedom end effector with a wearable three-finger exoskeleton for data capture. The system is built around three design goals: dexterity, consistency between collection and execution, and scalability. The project page is live at x2robot.com/pages/twindex.440
Tau Robotics2026-08-03 00:56:23Tau Robotics launches invite-only humanoid home cleaning service in San Francisco at $30 an hourTau Robotics, a U.S. robotics startup founded in 2024 and based in the San Francisco Bay Area, has unveiled an invite-only humanoid home cleaning service priced at $30 per hour. The company, which has fewer than 10 employees, previously raised about $3 million in a pre-seed round in September 2024. Videos released by the company show the robot washing its hands, dispensing soap, shutting off the tap, wiping surfaces, mopping floors, picking up trash and throwing it away. According to the source article, all of the videos were shown at normal speed rather than accelerated playback, which has been common in many home robot demos. The same report said the demonstrations were teleoperated rather than fully autonomous. Tau’s approach, as described in the article, is to use remote operation to bridge current capability gaps, enter real household settings earlier, and build a data loop from actual deployments. The company currently presents three service-focused humanoids — Chelsea, Elon and Tony — aimed at kitchens and bathrooms, recurring cleanup, and deep cleaning tasks respectively. The service remains limited in rollout, and consumer willingness to pay for a remotely operated humanoid with onboard monitoring in the home is still unclear.640